Map inspector
The inspector opens a map and lets you examine it without changing it. It is the tool for answering "is this map all right?" — before a change, after one, or when a robot is behaving oddly and the map is a suspect.
It has two modes: Inspect, for reading what a map contains, and Route, for testing that it can be navigated. Inspect draws the map either in 2D, the graph flat, or in 3D, the graph over the point cloud; the 2D/3D switch sits beside the mode tabs and appears in Inspect only. Route is 2D, and switching to it returns you to the flat view.
Opening a map
| Source | Use it when |
|---|---|
| Import from Fleet | The question is about a live site — this is the revision the fleet has activated for it. A robot that has not yet confirmed the change is still running the previous one |
| Upload TMG file | You have a graph on hand, without its other layers |
| Upload bundle | You have a full map bundle as a .zip |
Prefer importing from the fleet whenever the question concerns a real site. A copy on a laptop may be several revisions behind, and nothing will say so.
The map being inspected can be swapped without leaving the tool, and the header shows where the current one came from.
Reading a map
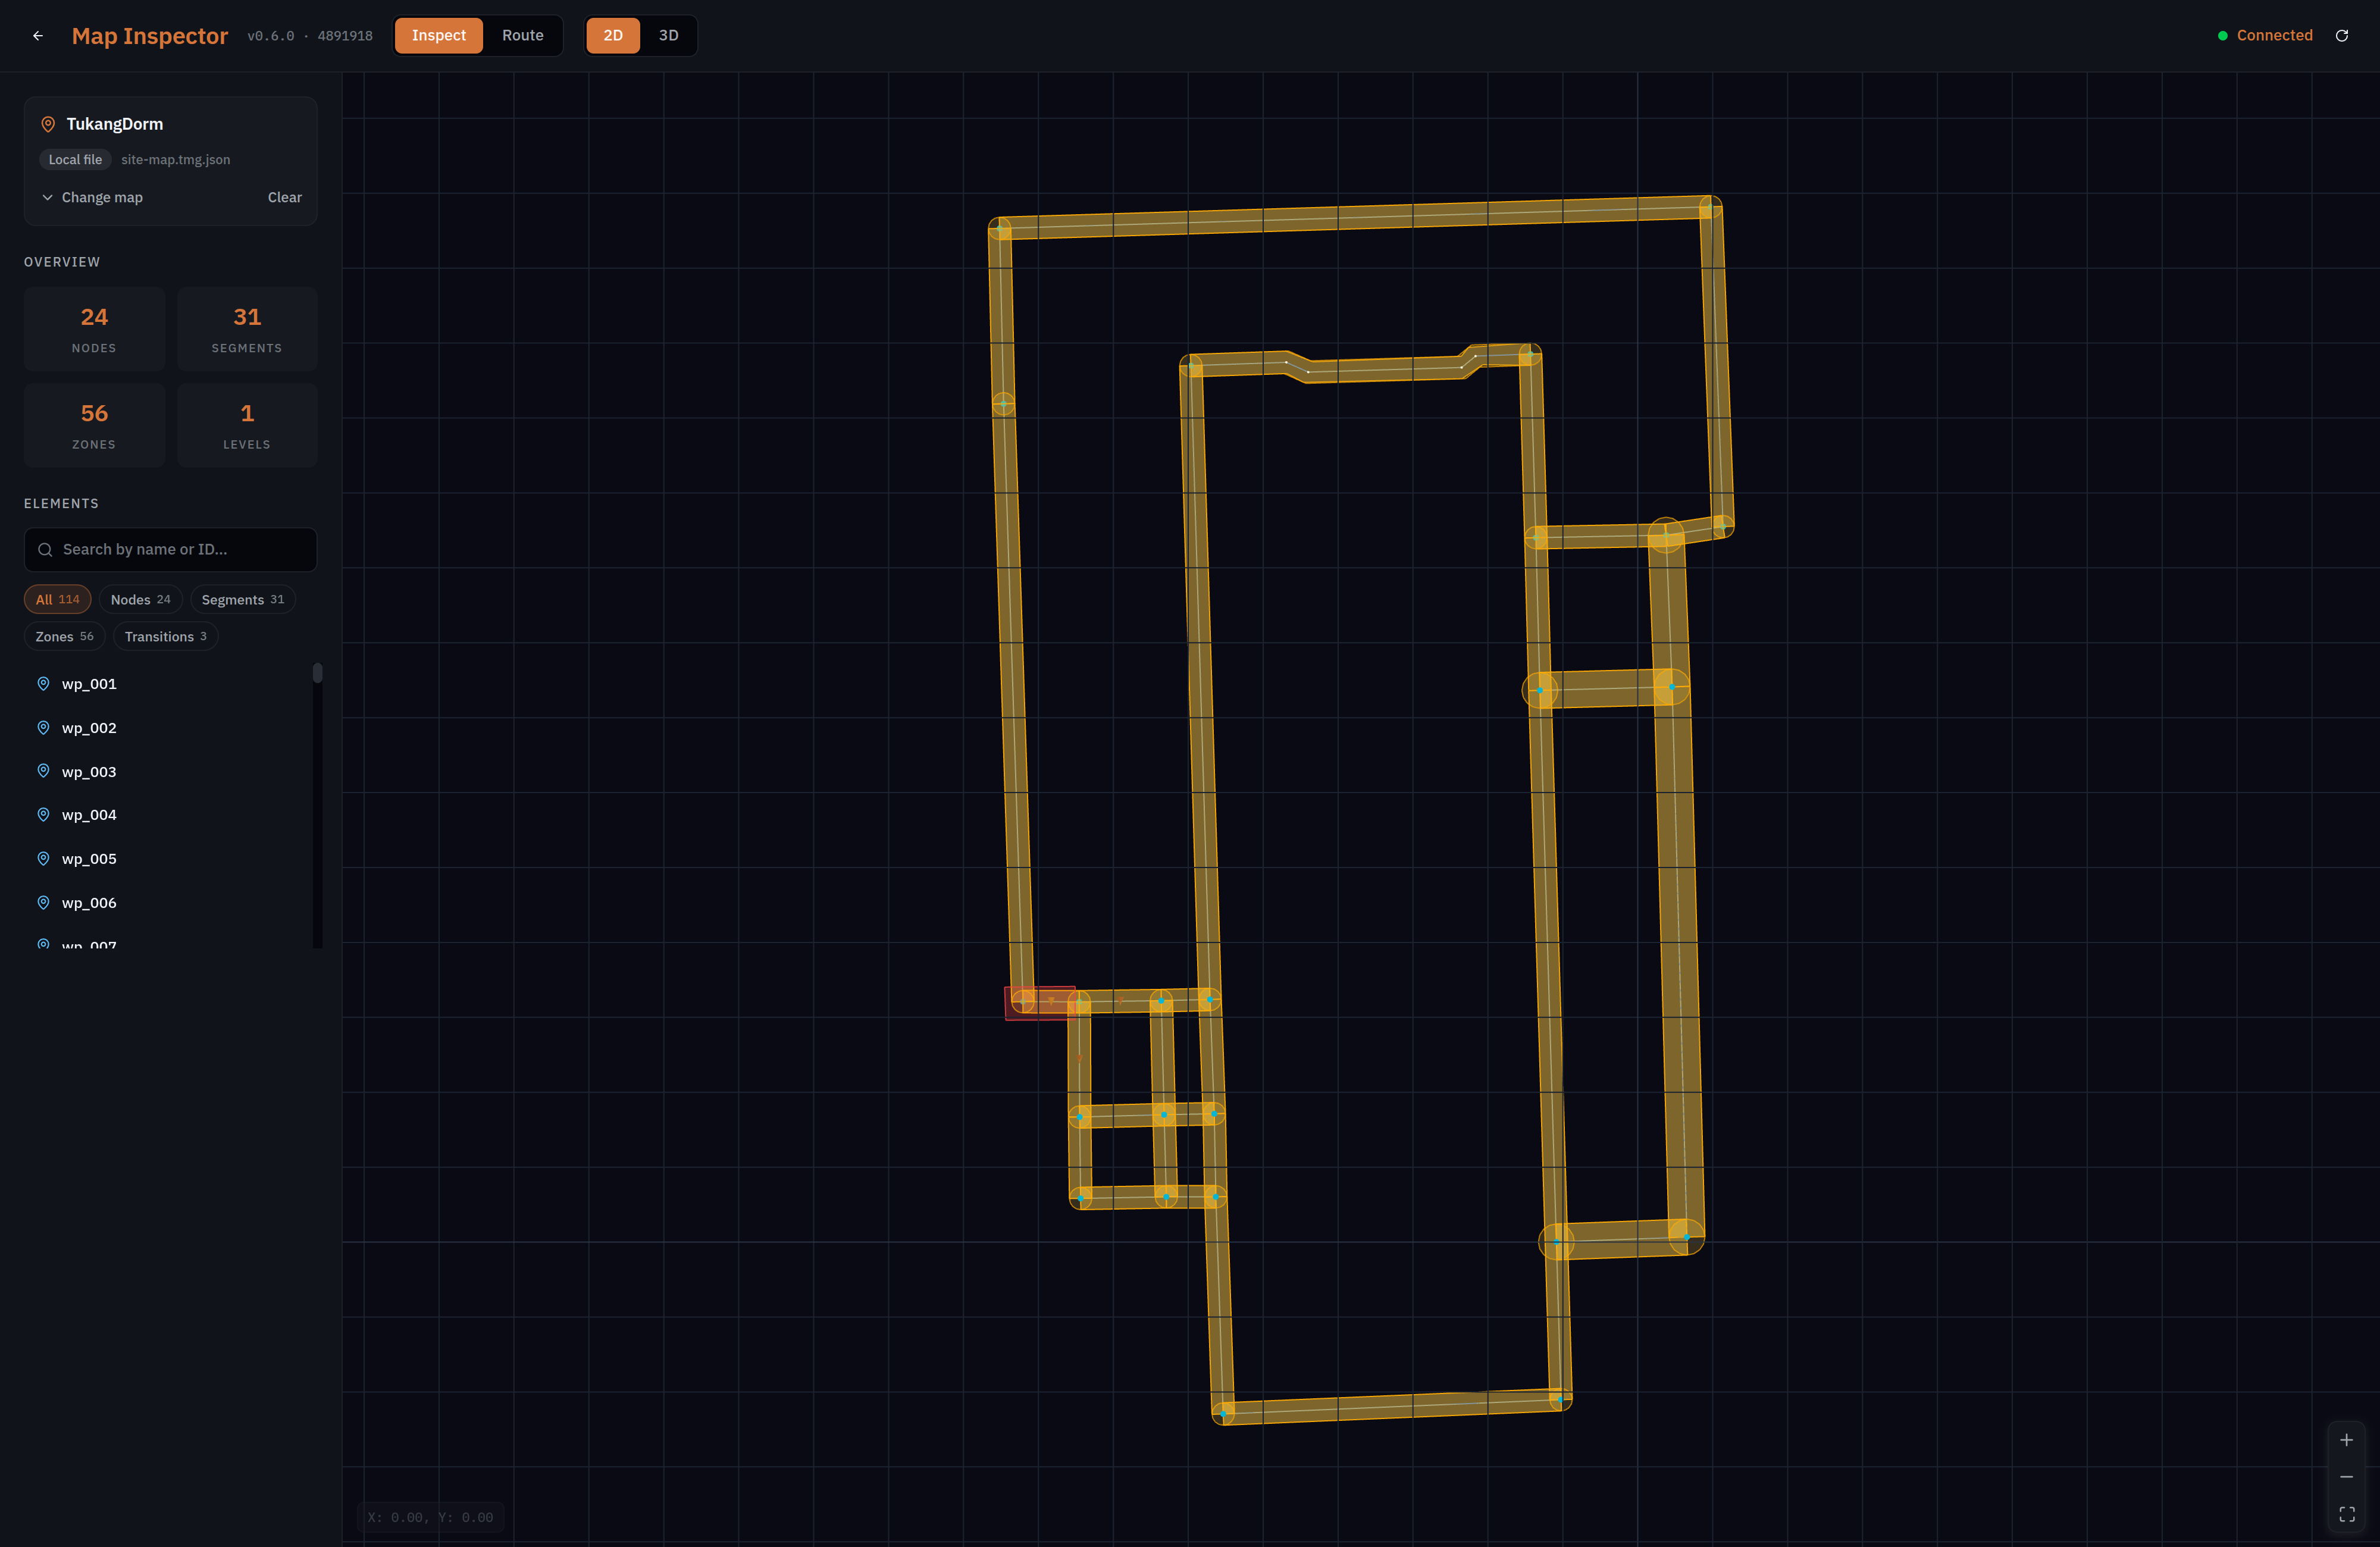
The overview counts what the map contains — nodes, segments, zones and levels — which is the quickest check that a map is the one you think it is. A site you expect to have a dozen nodes and which reports sixty is not the map you meant to open.
The element list is searchable by name or identifier and filterable by kind, so you can pull up every charging node, or find the one waypoint whose name you half remember. Selecting an element shows its properties.
This is also where naming elements earns its keep. A list reading wp_001 through wp_024 is searchable and tells you nothing; Loading Bay and Charging Point 2 are places a person can reason about, and the difference costs nothing at the time of drawing.
Testing that a route solves
Route mode answers the question the graph exists for: can the robot actually get from here to there?
Click to set a start point and shift-click to set a goal. The path is computed across the segments and drawn, or the attempt fails — and the failure is the informative case.
A route that does not solve is the map's problem, not the robot's. Two segments that appear to join on screen may not share a point; a path may cross a zone that forbids it; a node may sit on a different level from the one you expect. Each of those looks fine and navigates badly, and each shows up here in seconds rather than during a patrol.
Route planning runs as a service rather than in the browser, so the mode is unavailable when that service cannot be reached.
Route availability. Route requires both a connection to the supporting service and an available pathfinding engine. The header can therefore show Connected while Route remains unavailable — a real state rather than a glitch. The header itself reports three things and no more: Checking..., Connected or Offline; a server that is reachable but failing reads as Offline.
Test the pairs that matter, rather than every pair. The long paths — a charging bay to the far end of the site, and back — are what expose a break in the middle. Short hops between neighbours rarely tell you anything you did not already know from looking.
When to use it
| Situation | Why the inspector |
|---|---|
| Before publishing a change | Confirms the map you are about to push actually works |
| After activating a revision | Confirms what went live is what you meant |
| A robot will not go somewhere | Distinguishes a map that cannot express the route from a robot that will not follow it |
| Taking on an unfamiliar site | Reads the map someone else authored without risking an edit |
The inspector only reads. It never modifies a map, and it cannot push one back to the fleet — that is the editor's job. Opening a live site's map to look at it is therefore safe.
Common questions
Routes look connected but validation fails
Validation checks that a route actually solves, not that lines meet on screen. Two segments that appear to join may not share a point, or the path may cross a zone that forbids it.
Which map are the robots actually using?
Load it from the fleet rather than trusting a local copy — that is what Import from Fleet is for, and a copy on a laptop may be several revisions behind.
Route mode is greyed out
Route requires both a connection to the supporting service and an available pathfinding engine, and it is greyed out while either is missing. The header can read Connected and Route still be unavailable, because Connected reports only that the service was reached. On pointer-based browsers, hovering over Route may show which of the two is missing.