Robot Management Toolbox
The Robot Management Toolbox is the web application you run your robots from. Missions are planned here, dispatched here, watched here, and everything the robots find is kept here. It runs in a browser, and there is nothing to install.
A working deployment is the robots, the map they navigate by, and this system — the part your team uses every day. The Robot Deployment Toolbox prepares a site once, before any robot drives there. Detection algorithms — ours on the robot, or a partner's alongside it — report into this system too, so what they find arrives as events here.
The site map ties these parts together, and it travels one way: the Robot Deployment Toolbox pushes it here as a draft, an administrator publishes and then activates it, and robots receive it from here. The deployment toolbox never reaches a robot directly.
Key features of the system are summarized in the table below, and each is covered in its own section.
| Feature | What it gives you |
|---|---|
| Fleet overview | Every site and robot, with live status |
| Robot dashboard | Position on the site map, telemetry, camera feeds, health and activity |
| Robot teleoperation | Drive a robot from the browser, plus docking and posture commands — one operator at a time |
| Mission planning | Build missions from checkpoints, the actions at each and a schedule, and keep them in a library to reuse |
| Detection review | Everything the robots detected, filterable and reviewable, kept as a record that cannot be edited or deleted |
| Tenant management | Your sites and their robots, the maps they navigate by, the people who use them, and what each role may do |
| Audit log | An append-only record of who did what |
Admin and Operator roles
Two roles cover nearly all daily use: an Operator runs the robots, and an Admin decides what they are allowed to run. Admin here is the general term for a user with administrative permissions — at a single site that is a Site Admin, and a Tenant Administrator holds the same authority at every site. Roles defines all five roles and their scope, and names the exact role wherever an action requires one; the table below is the practical version — what each of the two everyday roles can actually do.
| What you want to do | Operator | Admin |
|---|---|---|
| Watch the fleet, a robot, its telemetry, its schedule and its history | Yes | Yes |
| Send a robot somewhere once — Quick Dispatch | Yes | Yes |
| Send a robot home — Go Home | Yes | Yes |
| Run a saved mission now | Yes | Yes |
| Send missions to a robot — Send to Robot | Yes | Yes |
| Turn a saved mission on or off | Yes | Yes |
| Change when a mission runs — its run conditions | Yes | Yes |
| Pause and resume auto-dispatch | Yes | Yes |
| Acknowledge work that failed | Yes | Yes |
| Catch a robot up to the map | Yes | Yes |
| Teleoperate, E-Stop, dock and undock, stance commands | Yes | Yes |
| Create or edit what a mission is — its route, checkpoints and actions | — | Yes |
| Create, rename, move or delete a saved location | — | Yes |
| Author, publish and activate a site's map | — | Yes |
| Change a robot's name, model, capabilities or assigned map | — | Yes |
The split is worth reading twice, because it is not the obvious one. Everything that commands a robot is an operator's to do — including sending missions to it, and including catching it up to the map. What an operator cannot do is change the definitions: the mission, the locations it refers to, and the map underneath both. So an operator can decide when a mission runs, and cannot change what it does.
An Observer may see all of the above and command none of it, with one deliberate exception: the E-Stop is available to every role at a site, and needs no control lease — though releasing it again is an Operator action. Every other action is enforced against the role you hold, so one outside your role cannot be performed. Taking control sets out the control panel and who may use each part of it.
Above a site. Managing people — creating users, granting roles and removing roles — is a Tenant Administrator's responsibility across the tenant, and needs no help from us. For creating tenants or sites, or registering or decommissioning a robot, contact Weston Robot support.
Some actions need more than a role. Holding the right role is necessary and sometimes not sufficient:
- Control is held under a lease. Commanding a robot means holding its controls; a second person cannot command it until the first releases them. See Taking control.
- The robot must be on the map the fleet activated. A robot that is behind has its dispatch and Go Home controls withdrawn until it catches up — Catching a robot up to the map.
- Go Home needs a home. Where none is set, the control reads Set Home instead.
- Pausing is easier than resuming. Auto-dispatch can be paused regardless of the robot's state. While the E-Stop is active, however, the auto-dispatch control is unavailable, along with the other controls that would start movement or take on new work. Resuming needs the robot's controls and a settled map, because resuming is a decision to let work start.
Admin standard workflow
Setting a site up, once. The map arrives first and the missions refer to it, so the order matters.
- Have the site surveyed and its map authored in the Robot Deployment Toolbox, which pushes it here as a draft.
- Publish and activate the map for the site — A site's maps.
- Get each robot onto that map — Catching a robot up to the map.
- Save the places the work refers to, and set each robot's home — Saved locations.
- Build the missions — Mission editing. Setting their run conditions need not be your job: an Operator can do it too. But a mission needs one before it can be activated, and only an activated mission is carried by the next step.
- Send the missions to the robots that will run them, and confirm the badge reads robot confirmed — Sending missions to a robot.
- Give your team their roles — Roles.
Operator standard workflow
Setting run conditions and running the robots.
- Open the Dashboard and look for anything that needs attention.
- Open the robot in question — Robot dashboard.
- Let the schedule run, or start something yourself: run a saved mission now, or Quick Dispatch the robot to one point.
- Watch it in Operations, and use Go Home or the E-Stop if you need to intervene.
- When a run fails, acknowledge it — and check that auto-dispatch is running again afterwards. Recovery and acknowledgement.
- Review what the robots found — Detection review.
Anything an operator cannot do on that path — a mission that needs a new checkpoint, a location in the wrong place, a robot that will not come onto the map — goes to an Admin. Where an action will not proceed at all, When an action cannot proceed explains what you are being told.
Fleet overview
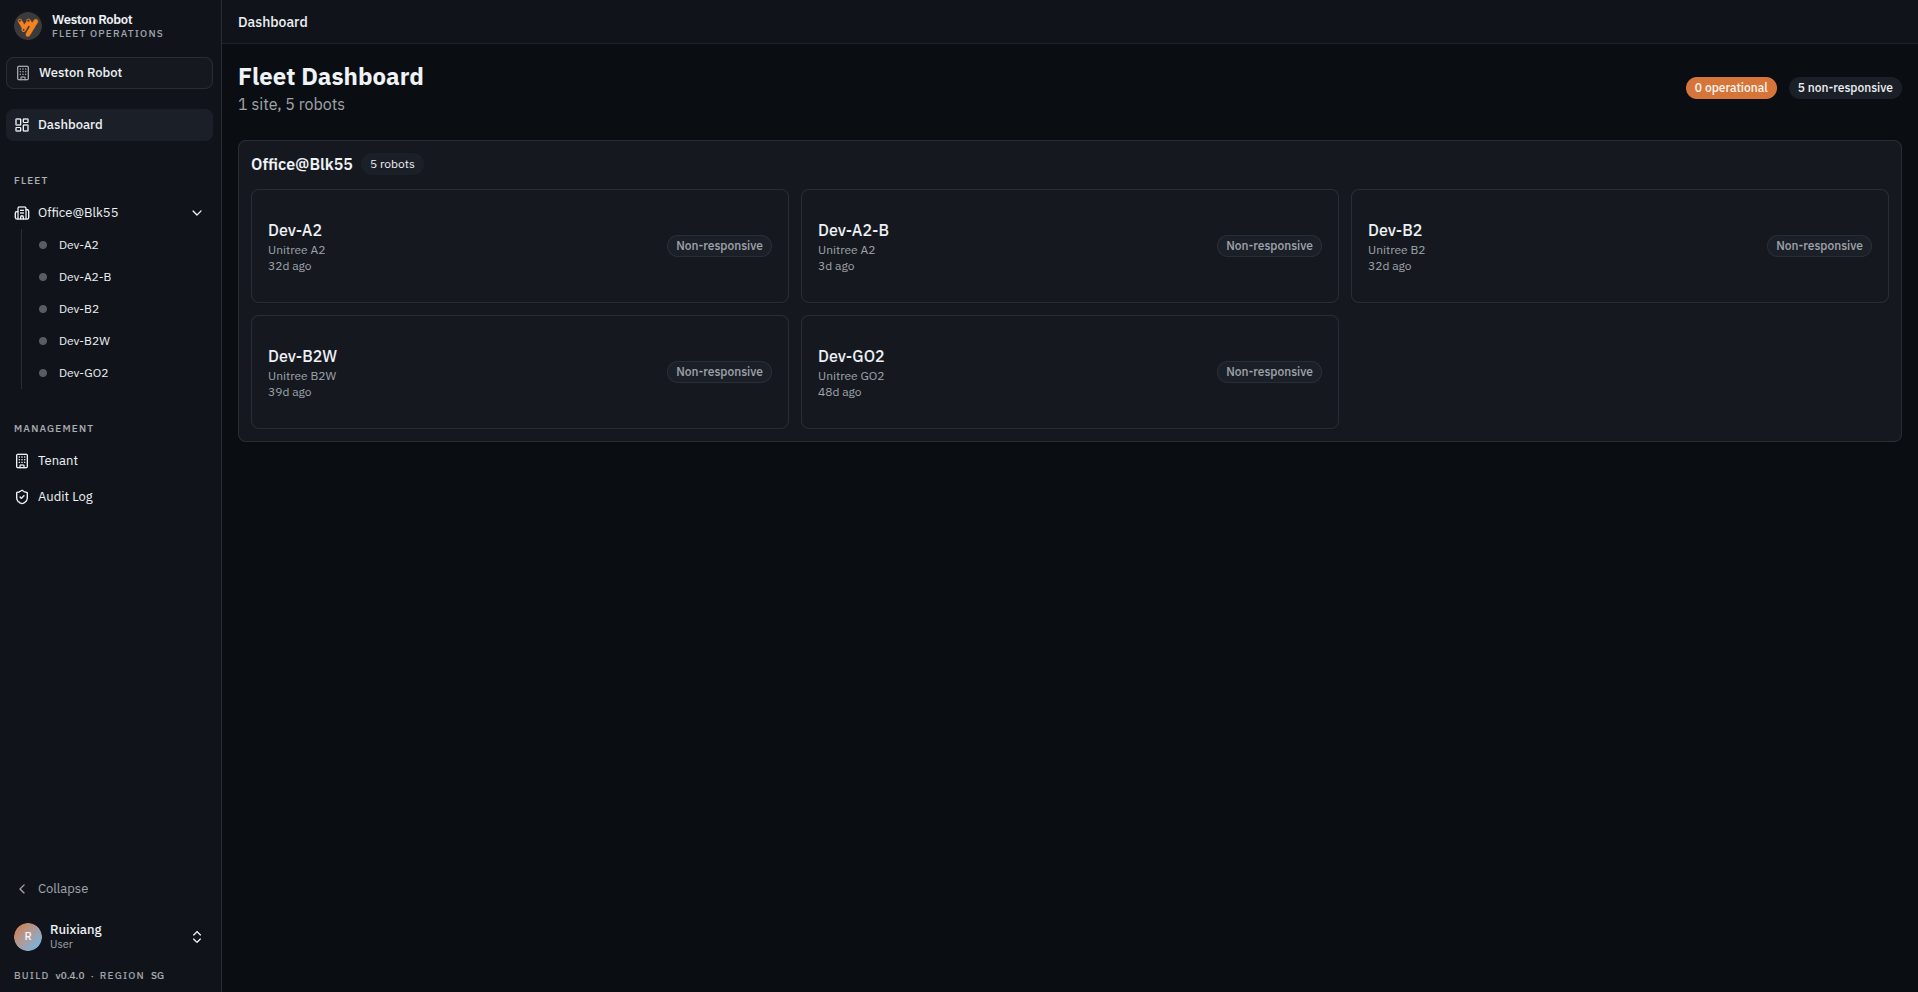
The dashboard is the entry point, and it is built around the question an operator asks first: is anything wrong right now? Sites run down the side, robots are grouped under the site they belong to, and a status count across the top summarises the whole fleet — how many robots are operational, how many are not responding, how many are faulty.
It is deliberately shallow: it tells you which robot needs attention, not why. One click into a robot opens the Robot dashboard, where the detail lives. The grouping is not cosmetic either — a site is the unit nearly everything else is scoped to, which Tenant management sets out.
Robot dashboard
Opening a robot gives you that one machine on one screen: where it is on the site map, what its cameras see, the mission running now, how it is holding up, and the controls to intervene. It is where an operator spends their time, and it is laid out so that judging a running mission needs no switching between tabs.
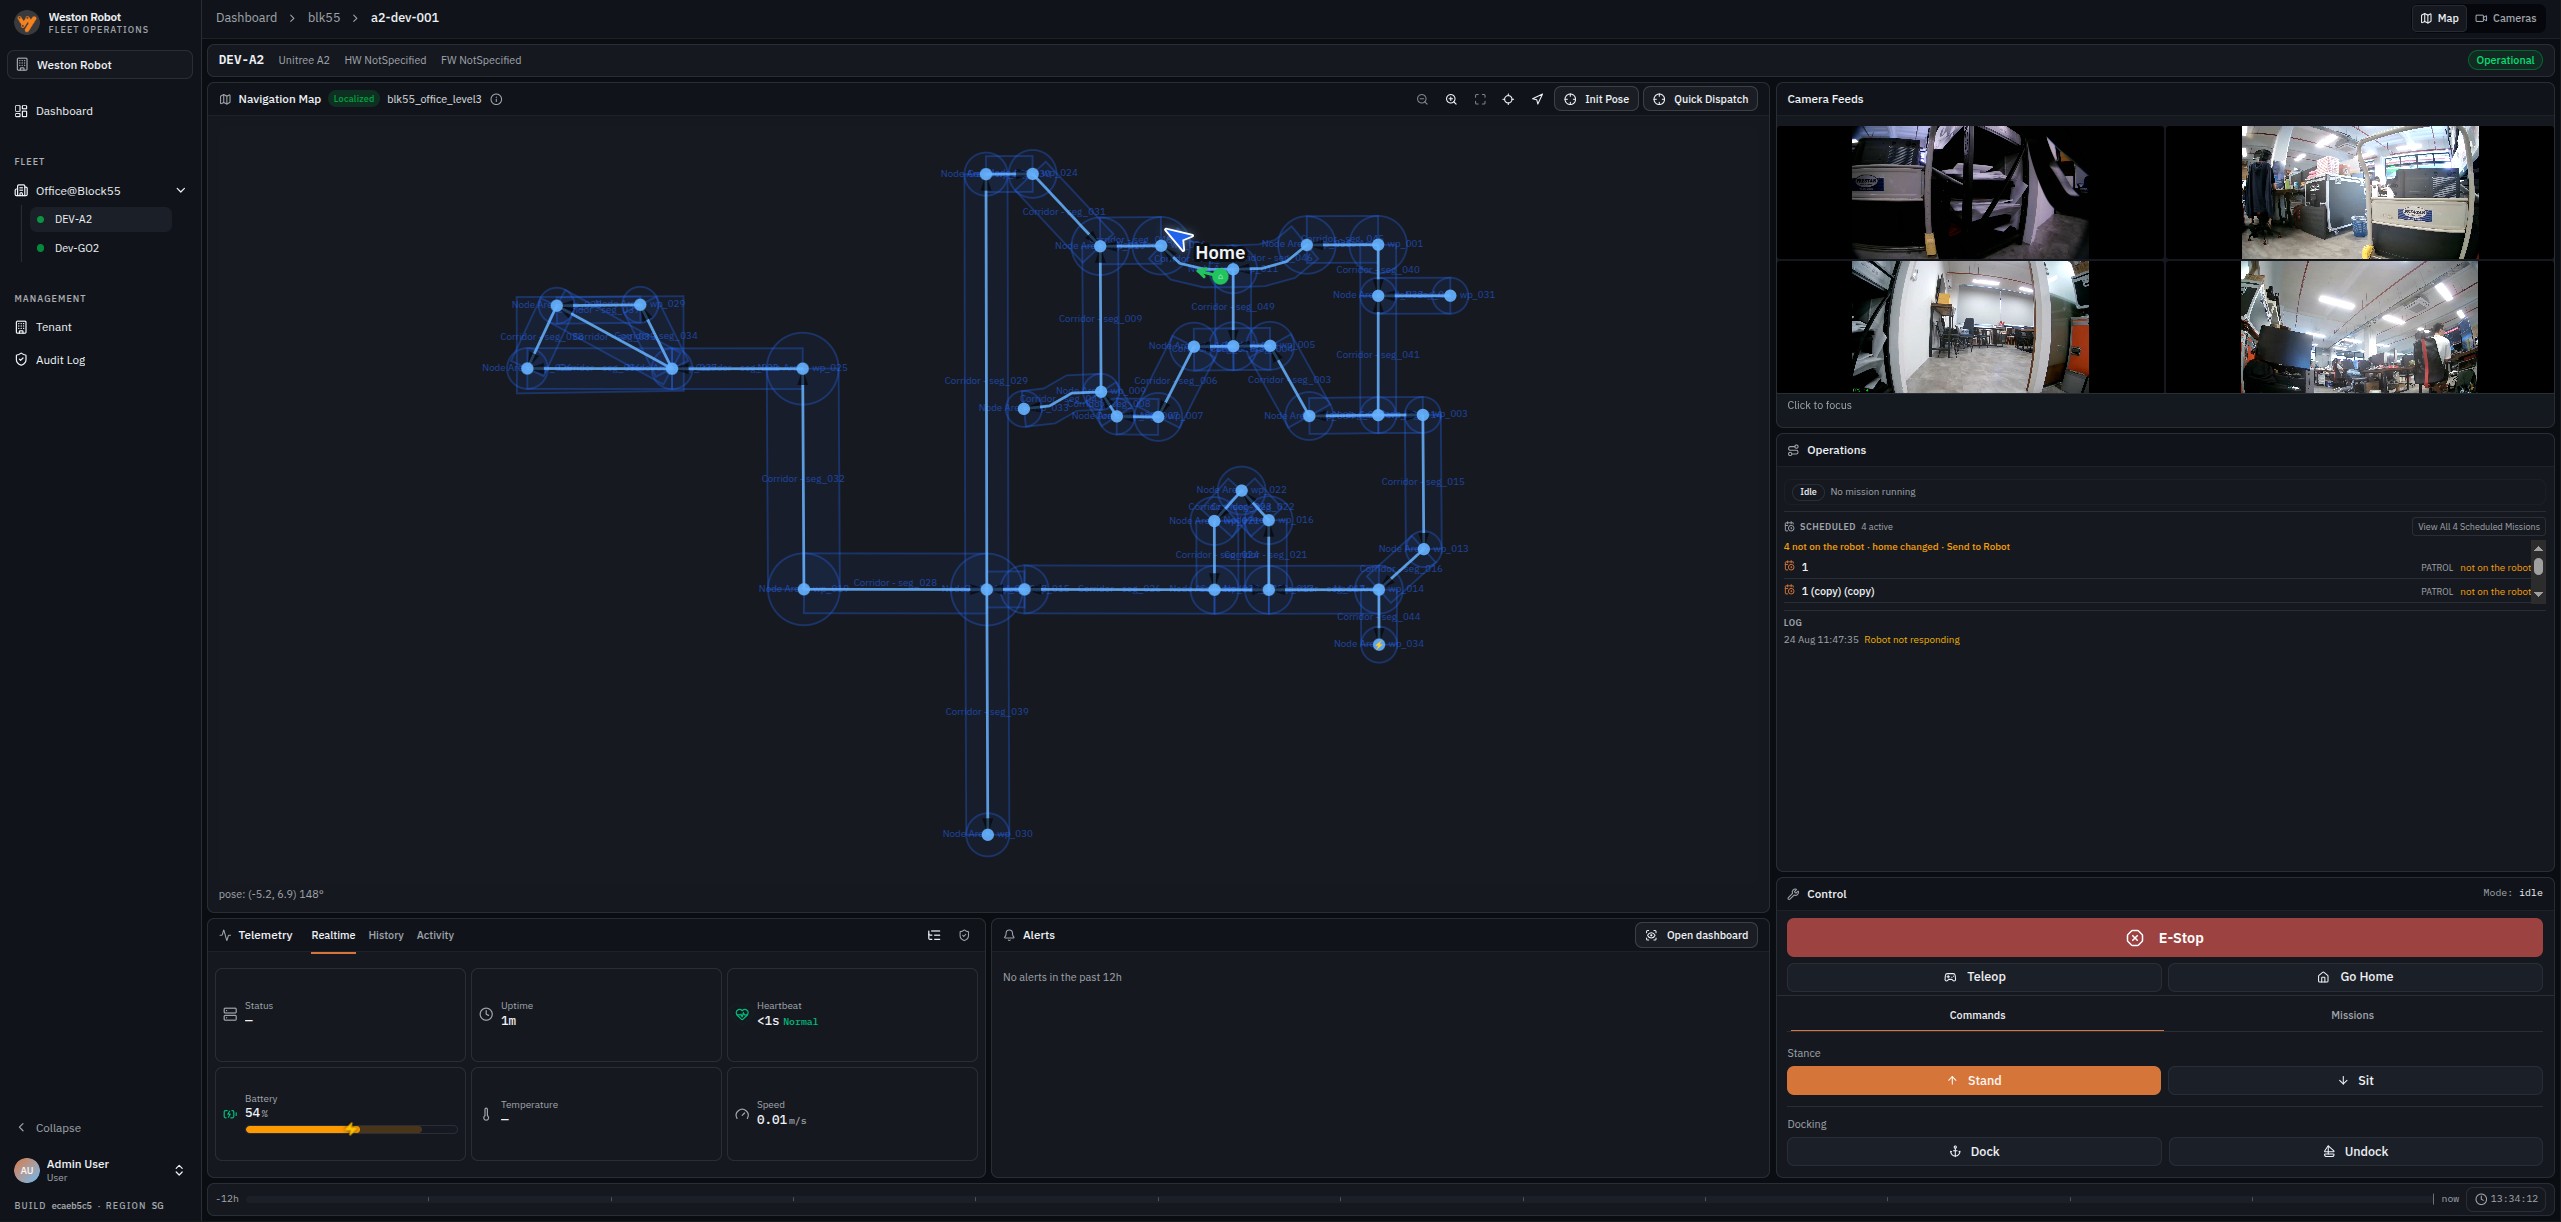
Robot dashboard covers the page in full: each panel, the telemetry readings and when a robot stops counting as reporting, the diagnostics view for a robot that is misbehaving, recovering localisation, arranging the camera view and the audio that goes with it, taking control of a robot, and what happens during a mission as battery level and the link to the fleet change.
Robot teleoperation
Beyond watching, an operator can intervene directly: drive the robot from the browser, stop it, send it home, dock it, or put it into a posture such as stand or sit. Because these commands move a machine in a real building, only one person holds a robot's controls at a time — with the E-Stop as the deliberate exception, available to every role at a site without taking the controls at all.
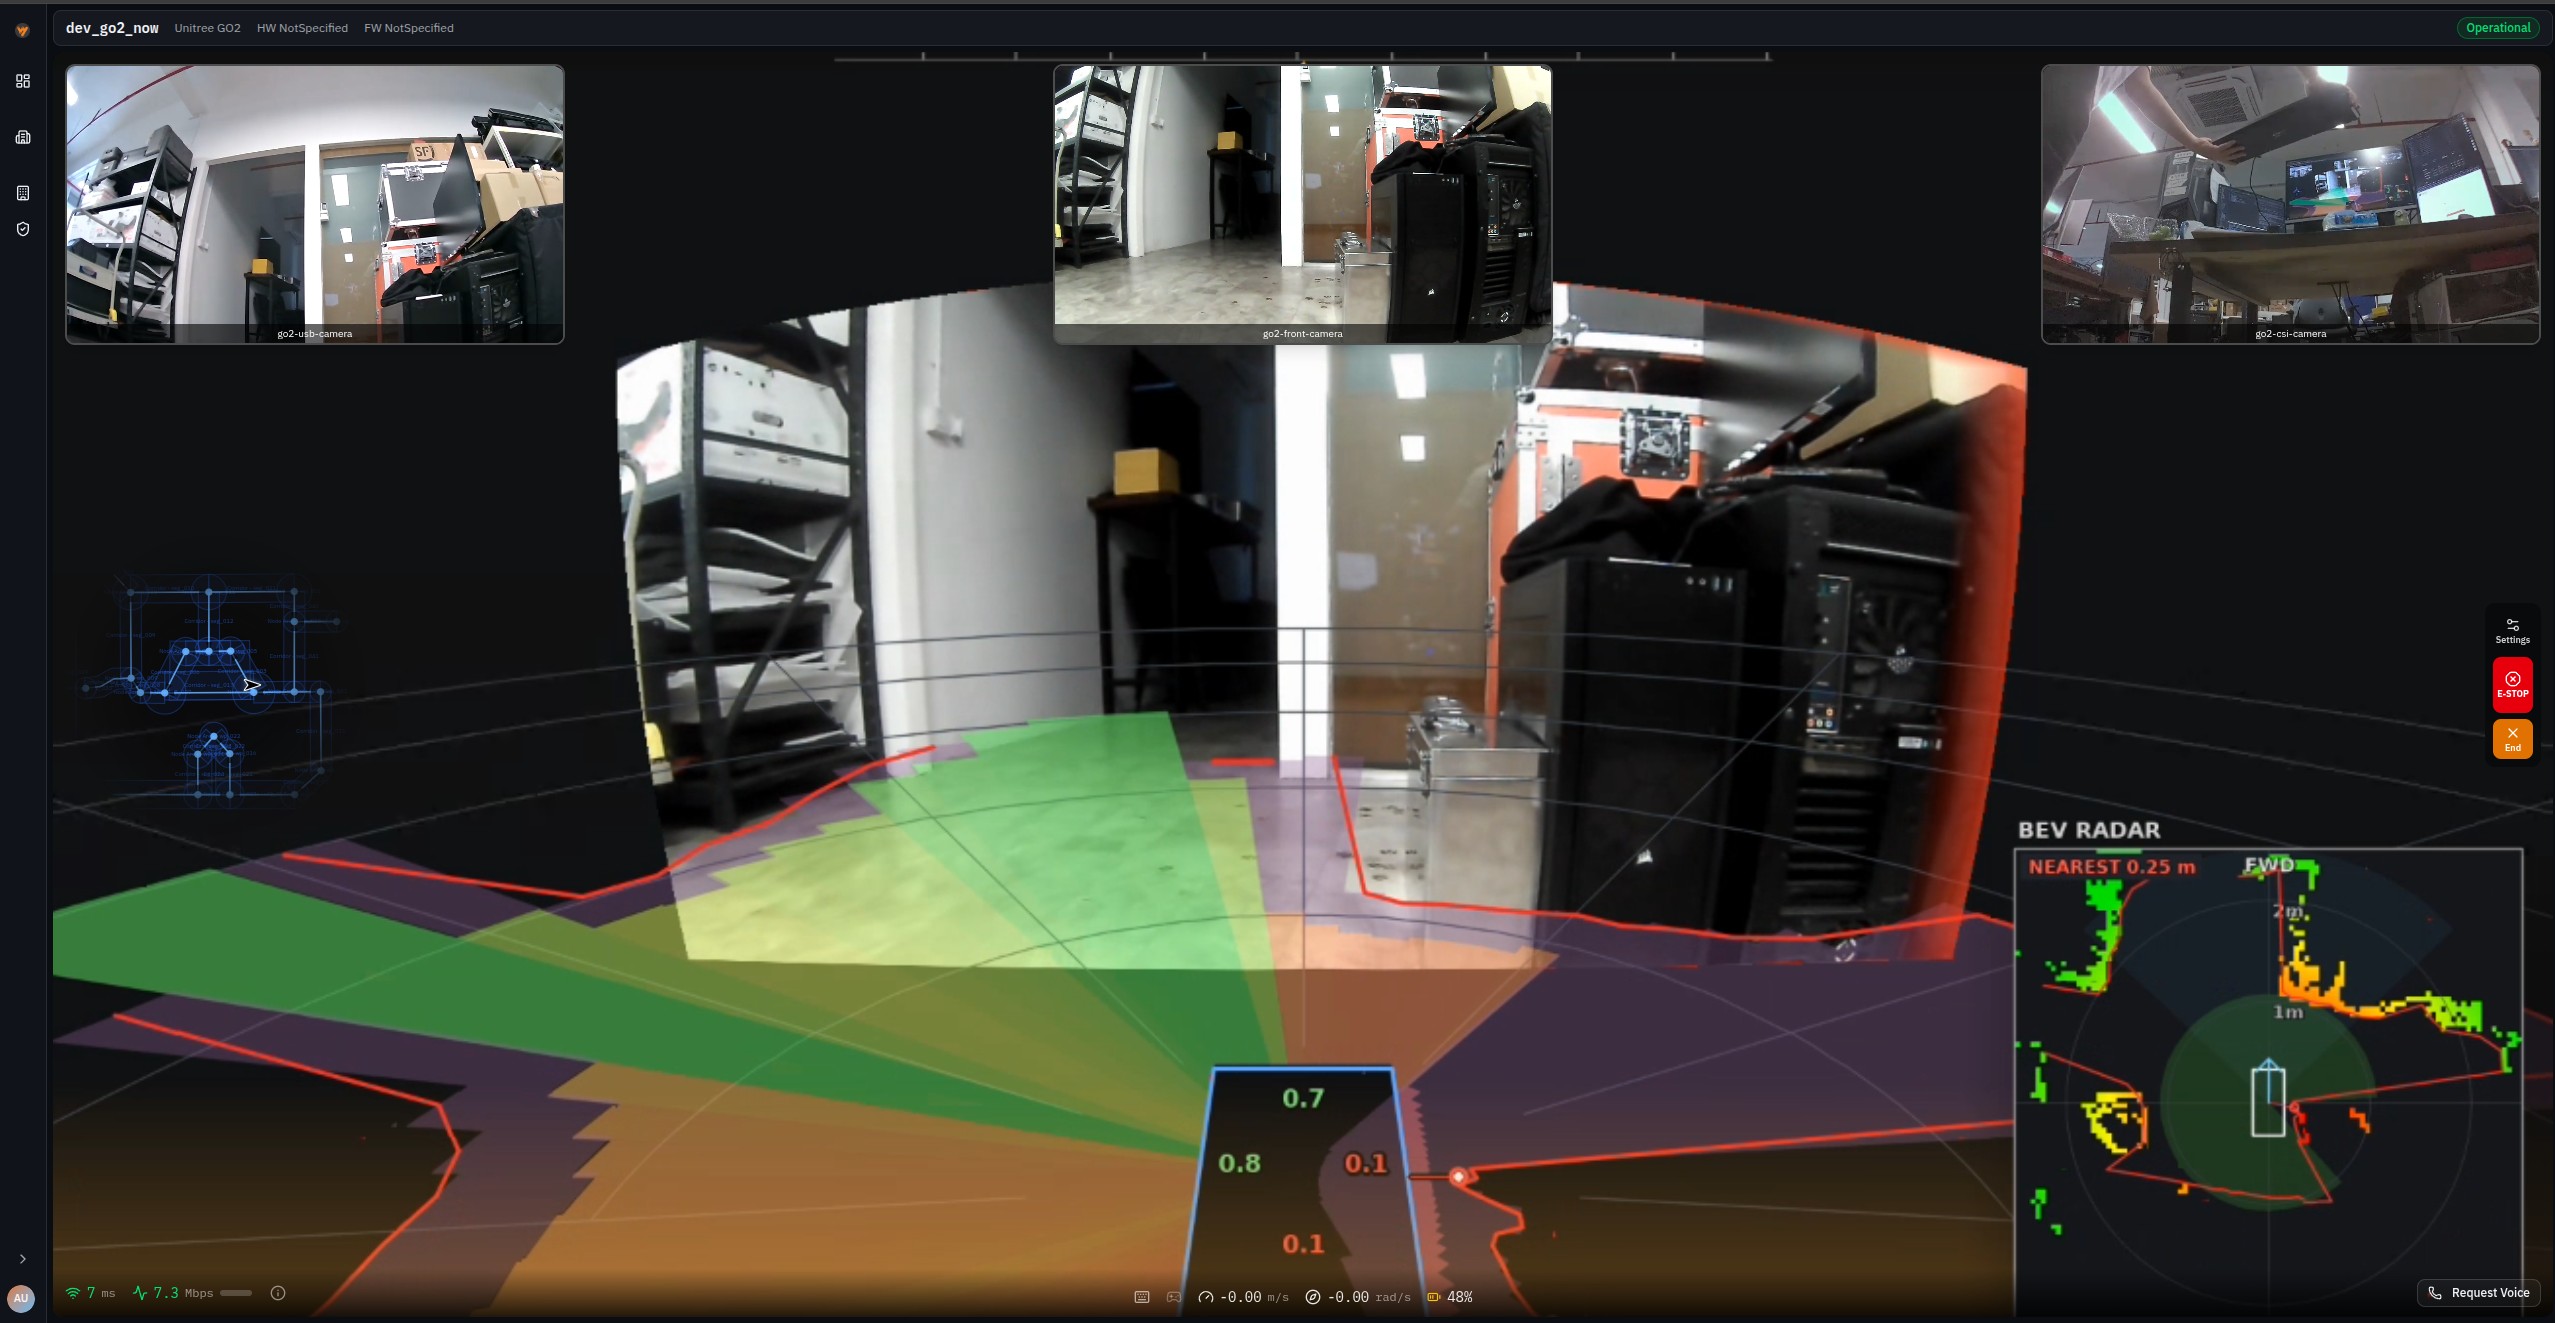
Robot teleoperation covers driving in full: keyboard and gamepad control, remapping and inverting the axes, speed and deadzone, speaking through the robot while driving, and the assisted view some robots present. The control panel itself — taking control, the E-Stop and who may release it — is on the Robot dashboard page.
Mission planning
A mission is an ordered list of places on the site map, what the robot does at each of them, and when it should run. It is the unit of work the system is organised around: built once, kept in a library, and reused rather than recreated. Dispatching hands one to a named robot, on demand or on its schedule; a robot can also be sent somewhere once, with no mission at all, through Quick Dispatch.
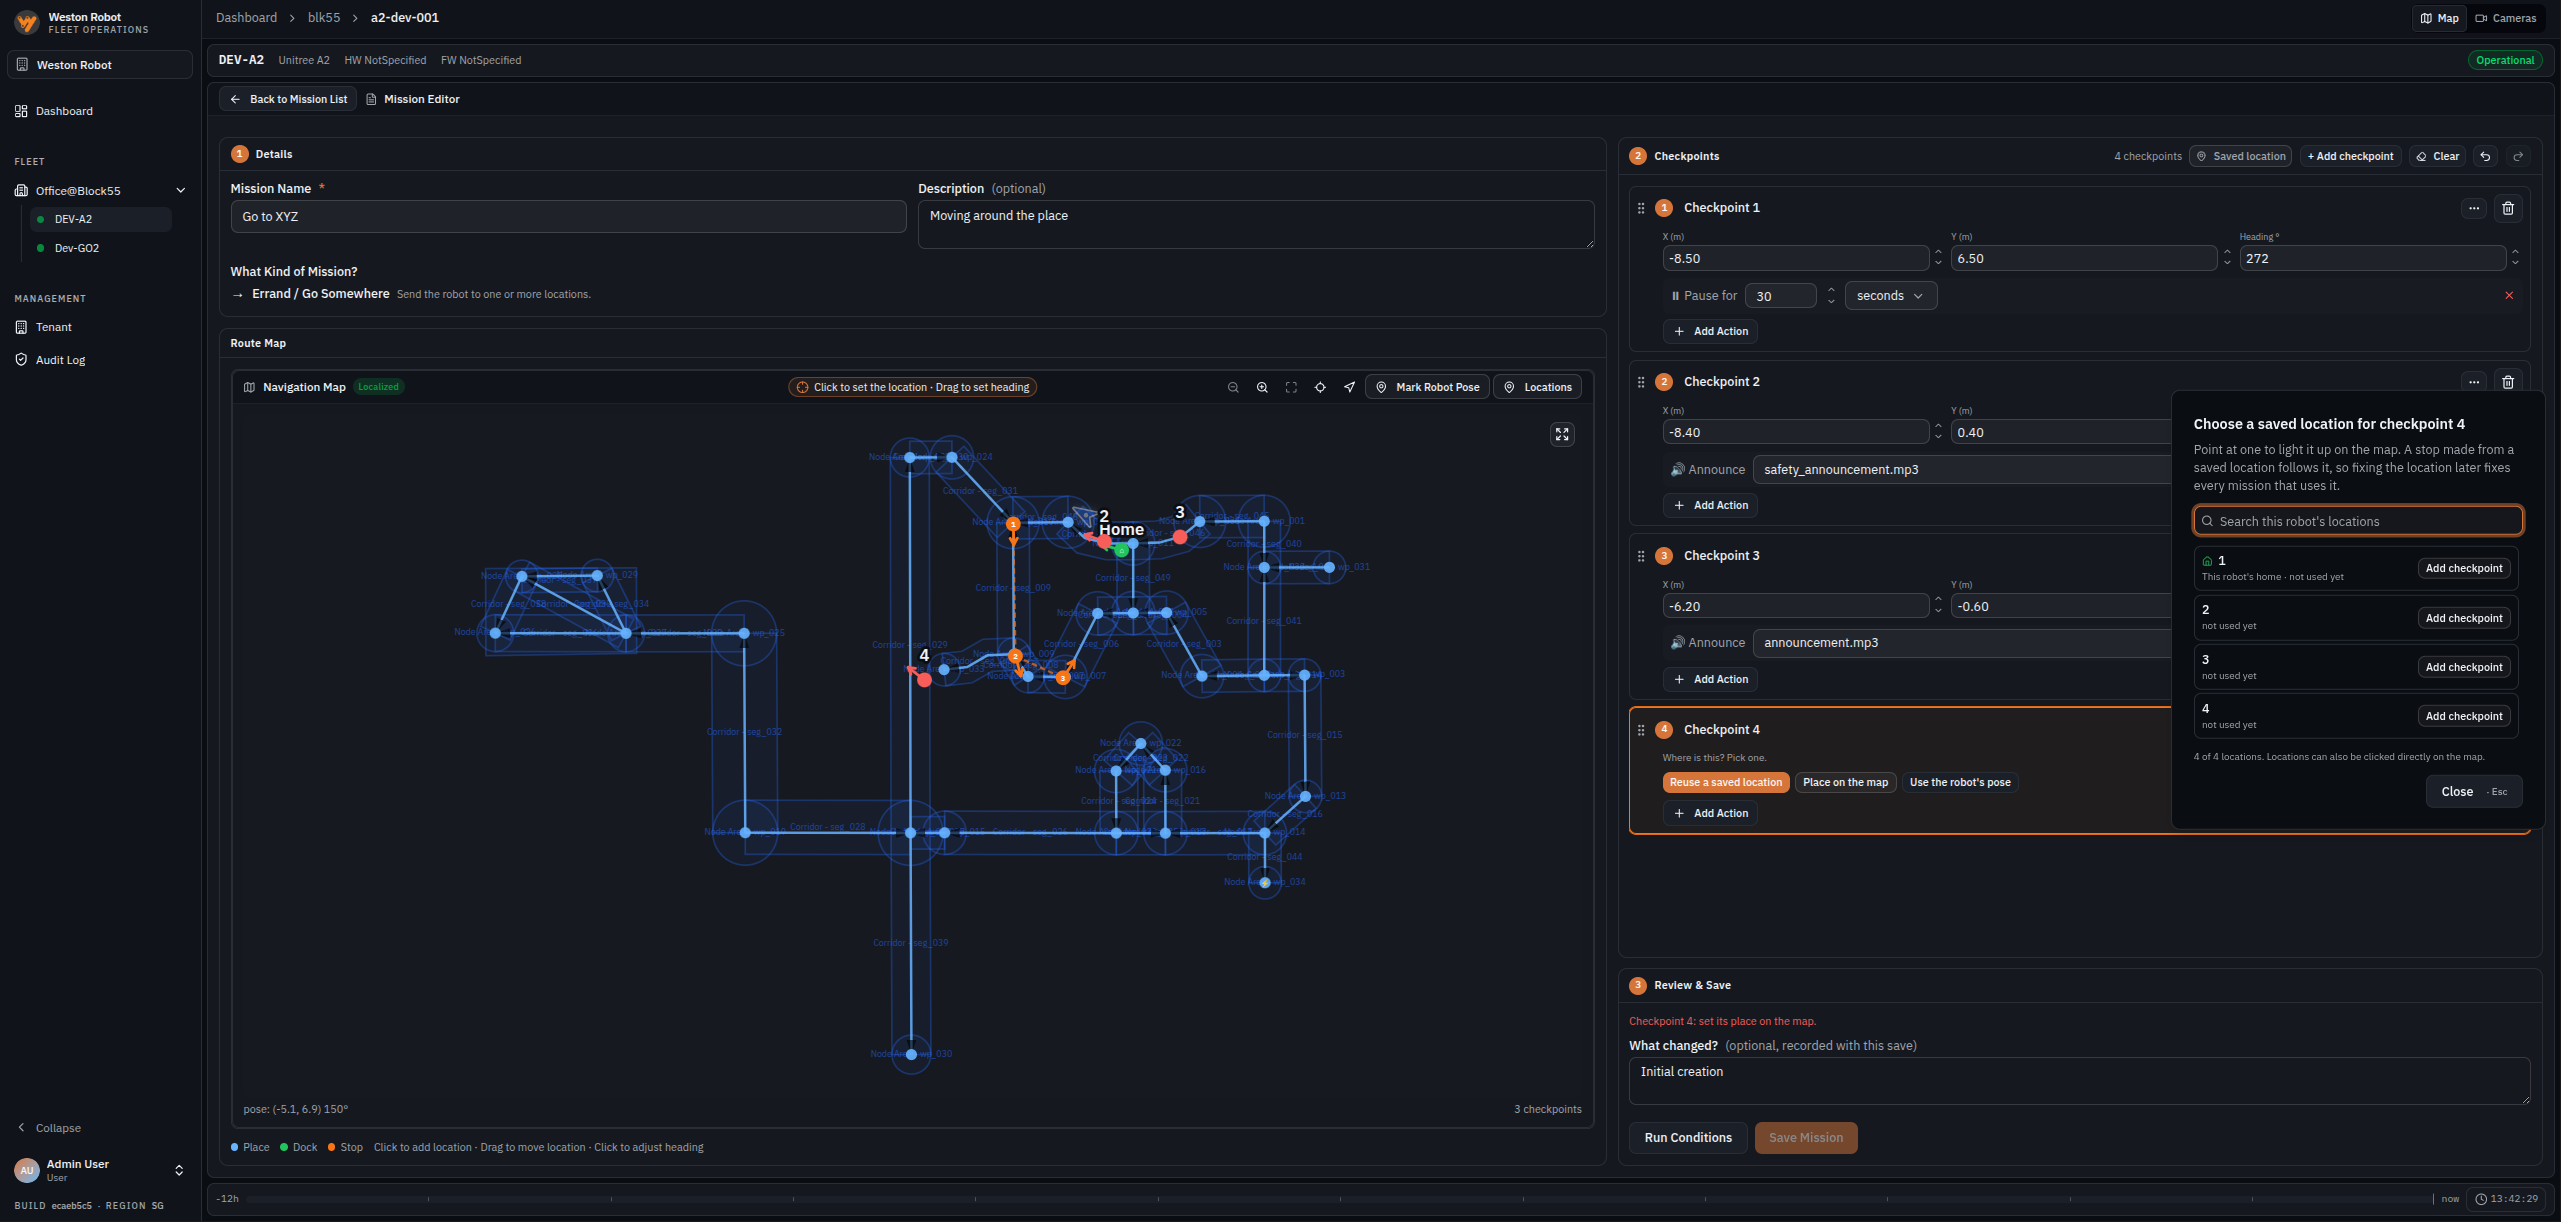
Mission editing and dispatch covers what a mission is made of, the editor's three stages, saved locations, run conditions and how they gate activation, sending missions to a robot and telling whether they arrived, and the history of what ran.
Detection review
Everything a site's robots observe is collected in that site's Detection Review, and stays there — whether a robot-mounted camera or an analytics service running elsewhere did the observing. What reaches an operator is decided by priority: an event carrying enough of it is raised into an alert, and everything else is kept and searchable without anyone being asked to look at it.
Records cannot be edited or deleted, and reviewer notes are appended rather than replacing what was there. That is what makes the list an evidence trail rather than a working queue: it will say the same thing when someone reads it back months later.
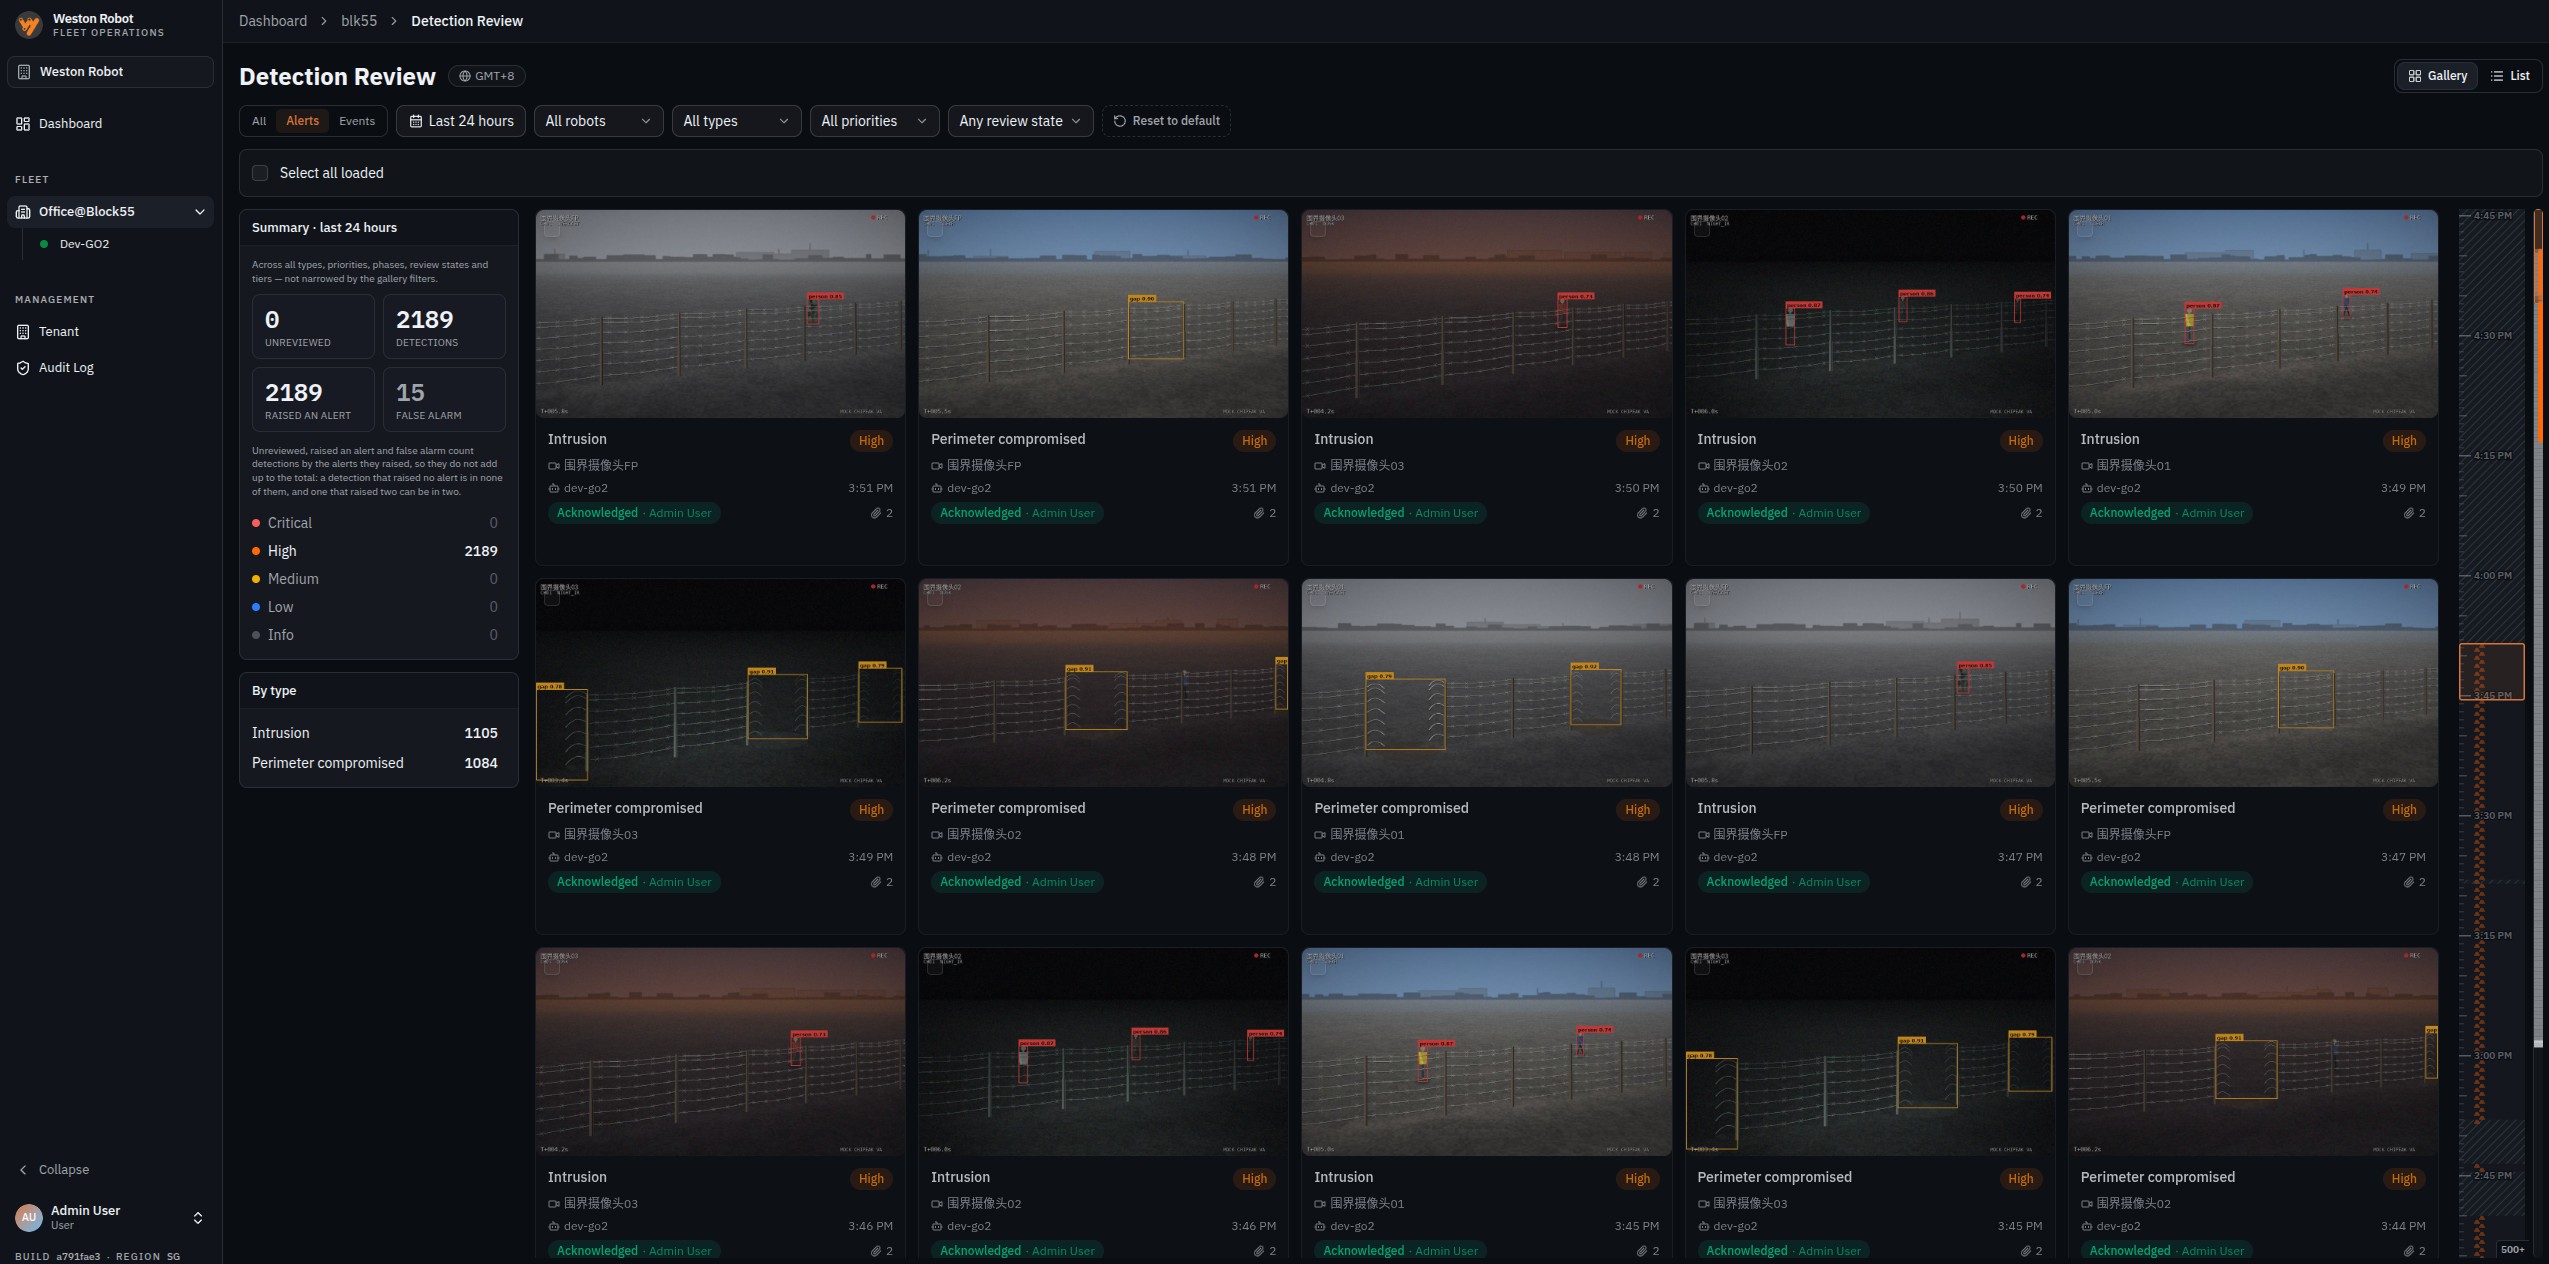
Detection review covers the difference between an event and an alert, lists every event type with the priority it carries and which of them raise an alert, and explains filtering, acknowledging and marking false alarms, and what each record keeps.
Tenant management
Your tenant is your organisation's own space in the system. Sites sit inside it, robots and maps belong to a site, and people are given roles within it — so seeing which robots and maps a site holds, activating a map, and granting somebody access are all the same job in the same place. Sites themselves are provisioned by Weston Robot rather than created here.
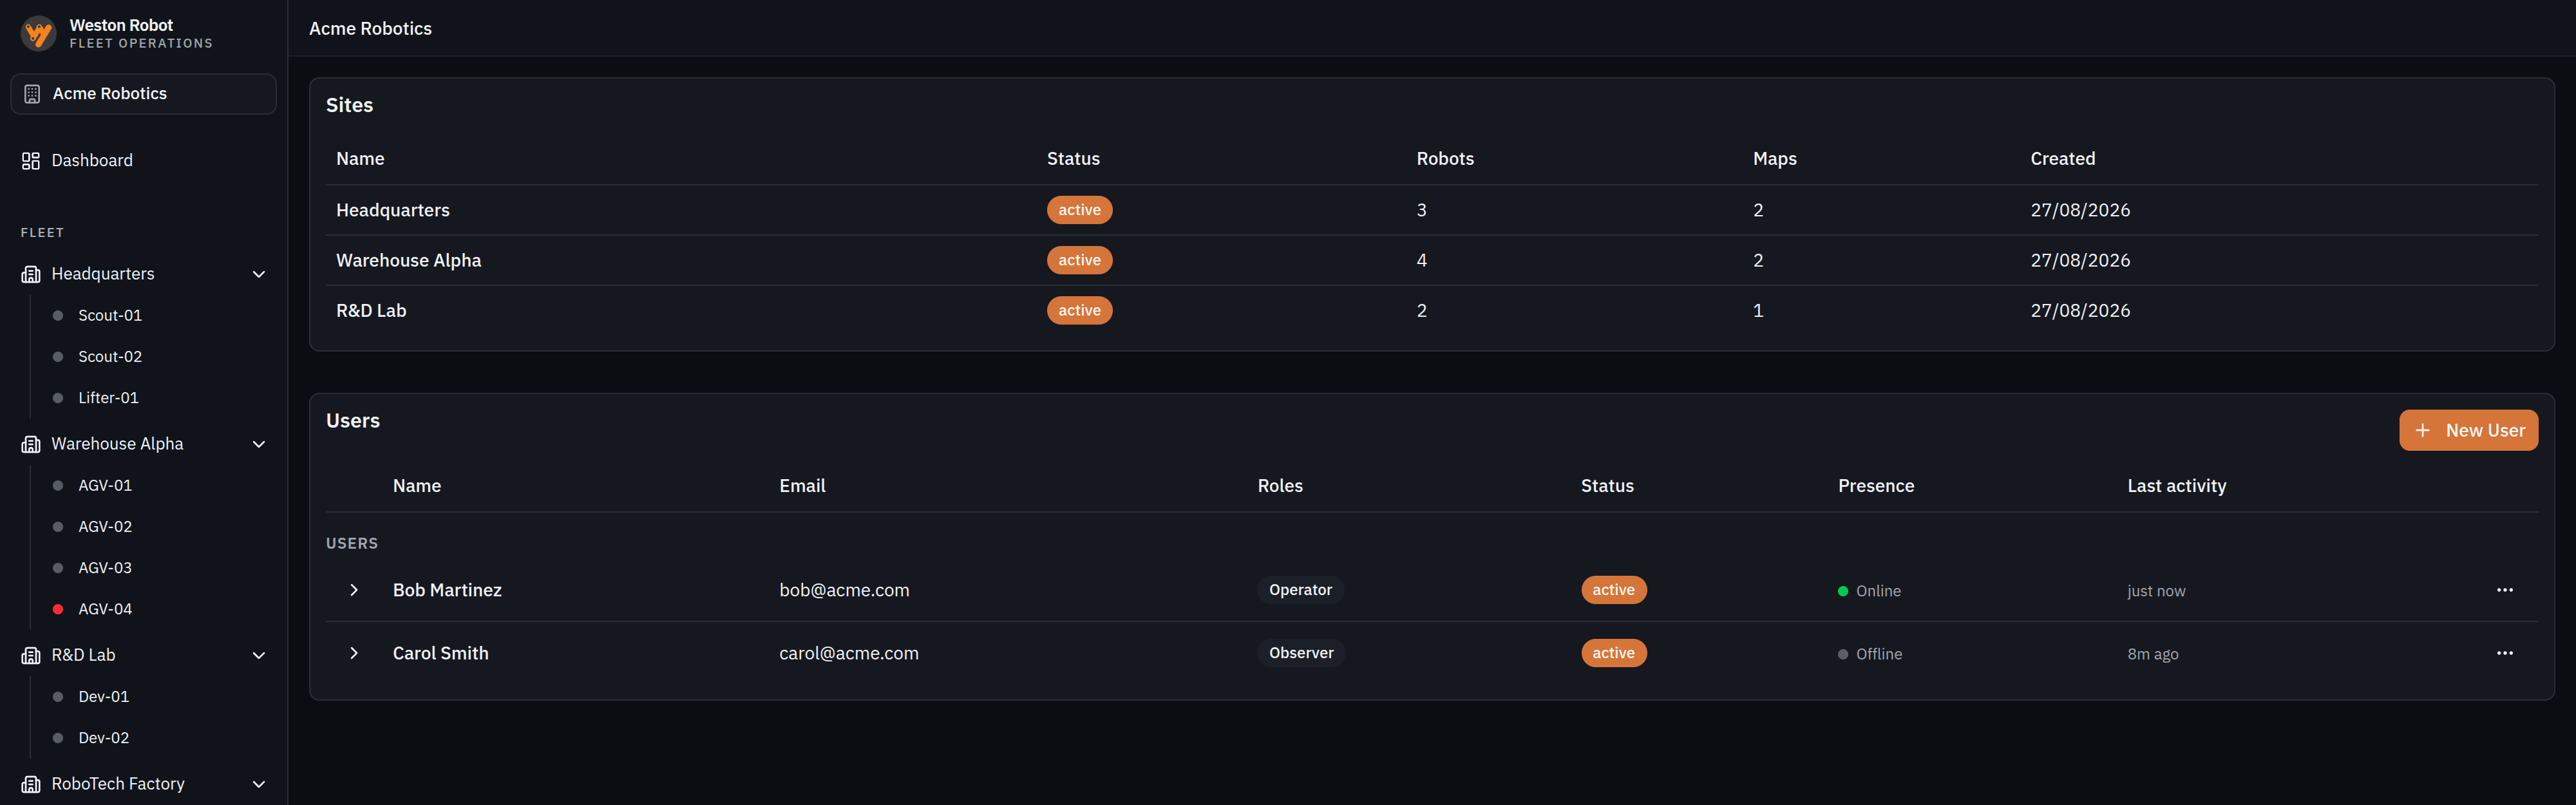
Tenant management covers how a tenant, its sites and their robots fit together, all five roles and what each may do, how a site's maps are revised and activated, and how a robot is assigned one and caught up when it falls behind.
Audit log
Actions are recorded in an append-only log: entries are added, never changed or removed. Together with detection records, which are stored the same way, it means the two things most likely to be asked about after an incident — what the robot saw, and what people told it to do — are both answerable from records that cannot have been tidied up afterwards.
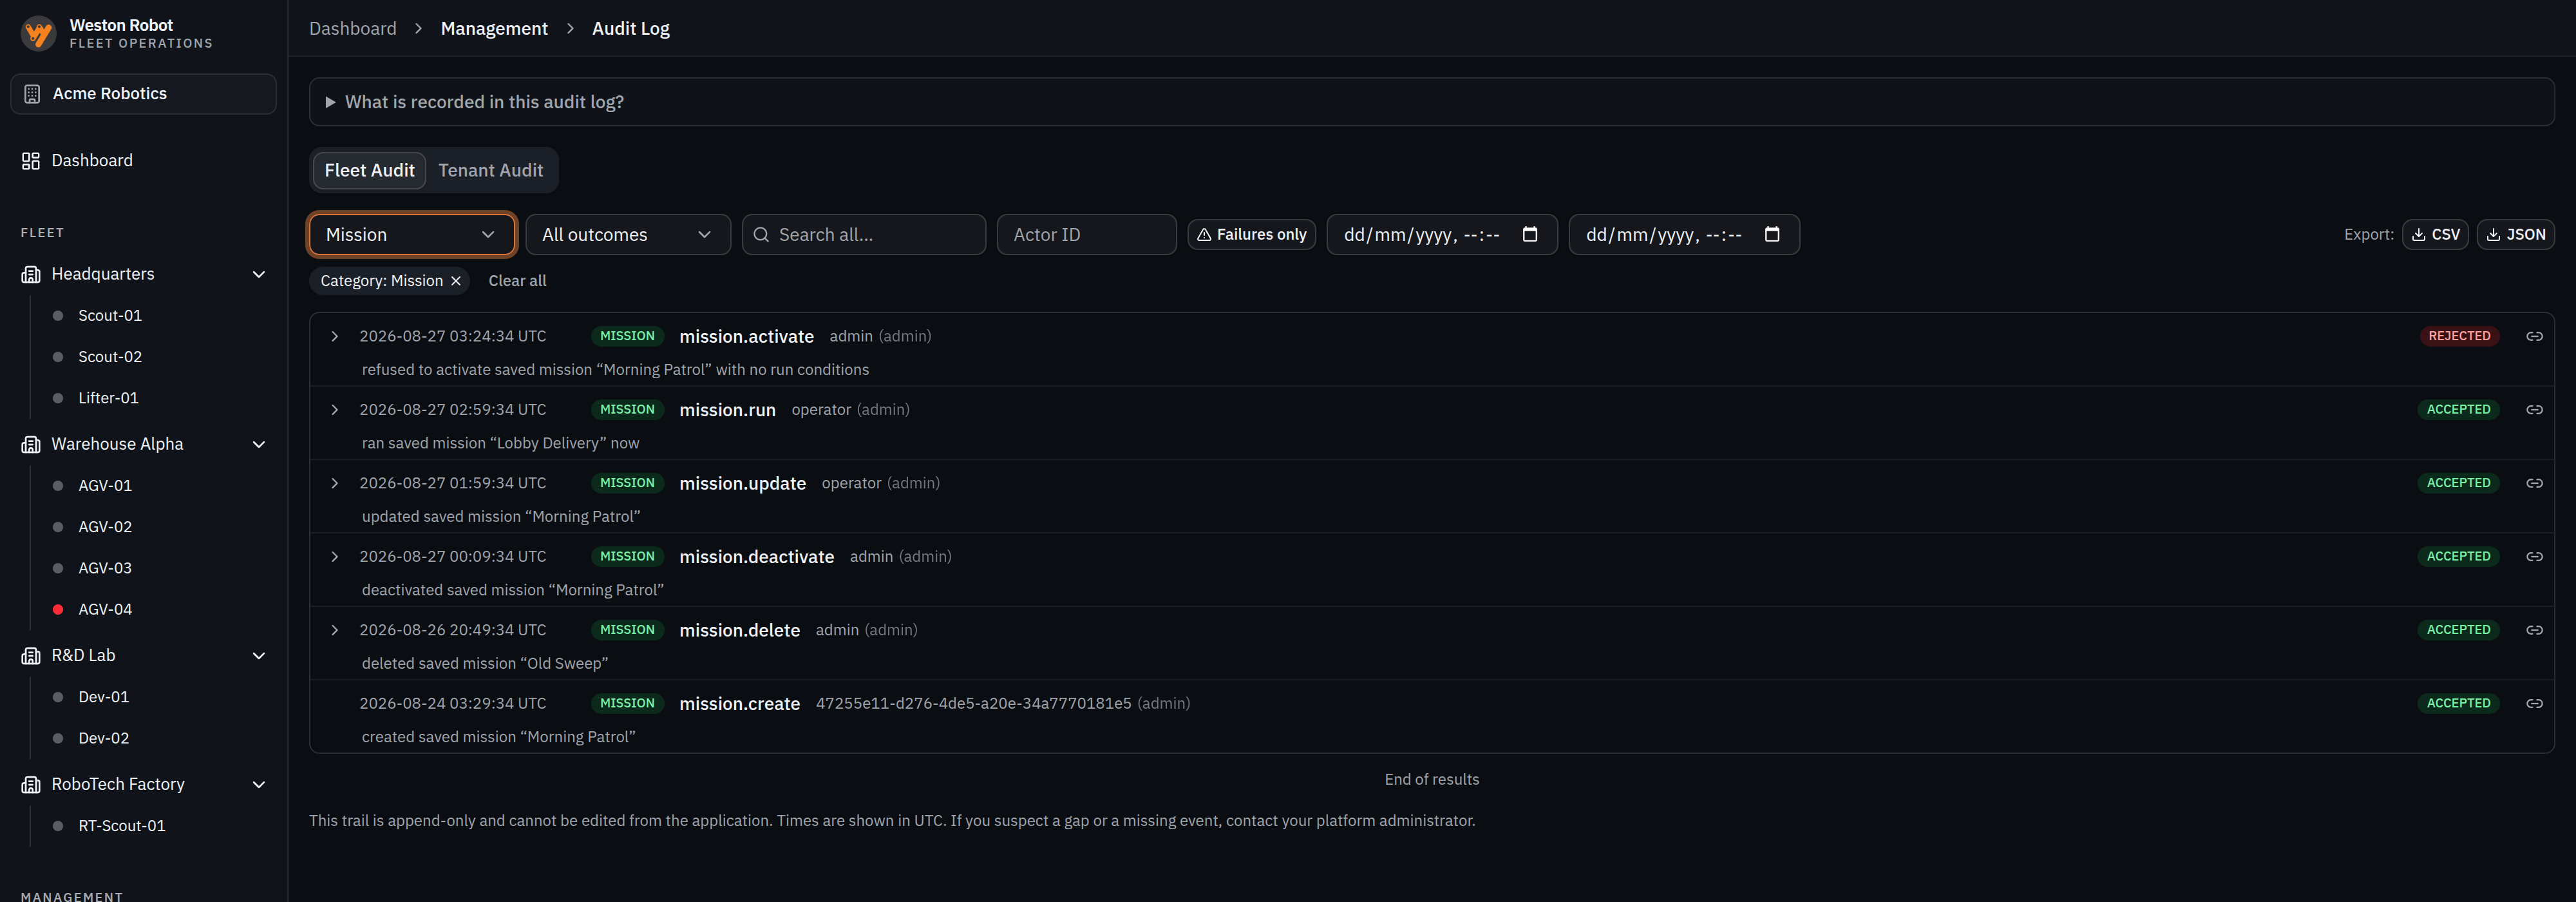
Audit log covers both trails — your own operations, and every visit Weston Robot staff made to your tenant under elevation — the categories entries fall into, pivoting to an actor, linking to a single entry, export and its limits, and the roles that can read them.
Further topics
Deployment and servicing — where the system runs (shared cloud, a dedicated cloud instance, or on-premise), what that decides about upgrade scheduling and data residency, and how robots and their software are kept current.
Known limitations
What the Robot Management Toolbox does not currently do. These are present limits rather than a list tied to one release: when one is lifted, this section changes.
A control you can see is not always one your role may use
Some operational controls stay visible to roles that cannot use them. An Observer holds no commands, and can still see controls such as Go Home or mission dispatch on a robot's panel. Pressing one does not carry it out — authority is checked when the action is sent rather than by hiding the control, so the action is refused and the robot is not touched.
Read Roles as the authority on what someone may do, rather than reading it off their screen.
No level to choose
No level is chosen or reported anywhere in this toolbox. The places you save and the missions you build belong to the level the robot is operating on — whether a deployment can span floors or elevations carries the scope.
Built for a desktop browser
The Robot Management Toolbox is designed and tested for desktop browsers. Some views adapt to smaller screens, but tablet and phone use is not currently supported for normal operation. In particular, mission editing and robot teleoperation require a desktop or laptop workflow.
Use a desktop or laptop browser when planning missions, operating robots, or carrying out administrative work.
Limits stated where you meet them
Three more belong to a single workflow each, and are explained at the point they matter:
| Limitation | Where it is covered |
|---|---|
| Go Home can still report work as staged while the robot is already driving home | Taking control |
| Save Mission does not say why it is unavailable — most often a missing mission name | Review & Save |
| Moving a saved location on top of another is not checked the way saving one is, so a move can leave two locations at one place | Saved locations |
Support
Before raising a ticket, note which site and robot are involved, what the robot was doing just before, and what you saw on screen. Before you contact us lists what helps and how to submit a support request.